
Directory · #141 trending skills repo · ↗ +150 stars this week
Planning With Files
OthmanAdi/planning-with-files
Persistent file-based planning for AI coding agents and long-running tasks. Crash-proof markdown plans, session recovery after /clear and compaction, per-turn re-injection against context rot, deterministic completion gate. Manus-style. Install from npm, the Claude Code plugin marketplace, or npx skills. Codex, Cursor, OpenCode, 60+ agents.
- Stars
- 28k
- This week
- +150
- Forks
- 2.3k
- Open issues
- 6
- Skills inside
- 18
Get started
Install the skills
npx skills add OthmanAdi/planning-with-files --skill planning-with-files -gInstalls into Claude Code, Codex, Cursor, OpenCode and the other agents it finds on your machine.
/plugin marketplace add OthmanAdi/planning-with-files
/plugin install planning-with-files@planning-with-filesRun inside Claude Code, then pick what to install from /plugin.
git clone --depth 1 https://github.com/OthmanAdi/planning-with-files.git /tmp/planning-with-files
cp -r /tmp/planning-with-files ~/.claude/skills/planning-with-filesClaude Code reads ~/.claude/skills/ (or .claude/skills/ in a project). Other agents read the same SKILL.md format from their own skills folder.
Inside this repo
18 skills
.agents/skills/planning-with-files⬇ 377 installsplanning-with-filesPersistent file-based planning for multi-step AI-agent work. Keeps task_plan.md, findings.md, and progress.md on disk; lifecycle hooks inject selected project planning context. Automatic recovery reads project planning files only. Explicit session-catchup.py --metadata reads same-project local agent.codebuddy/skills/planning-with-files⬇ 377 installsplanning-with-filesPersistent file-based planning for multi-step AI-agent work. Keeps task_plan.md, findings.md, and progress.md on disk; lifecycle hooks inject selected project planning context. Automatic recovery reads project planning files only. Explicit session-catchup.py --metadata reads same-project local agent.codex/skills/planning-with-files⬇ 377 installsplanning-with-filesPersistent file-based planning for multi-step AI-agent work. Keeps task_plan.md, findings.md, and progress.md on disk; agent instructions read selected project planning context when invoked. Automatic recovery reads project planning files only. Explicit session-catchup.py --metadata reads same-proje.continue/skills/planning-with-files⬇ 377 installsplanning-with-filesPersistent file-based planning for multi-step AI-agent work. Keeps task_plan.md, findings.md, and progress.md on disk; lifecycle hooks inject selected project planning context. Automatic recovery reads project planning files only. Explicit session-catchup.py --metadata reads same-project local agent.cursor/skills/planning-with-files⬇ 377 installsplanning-with-filesPersistent file-based planning for multi-step AI-agent work. Keeps task_plan.md, findings.md, and progress.md on disk; lifecycle hooks inject selected project planning context. Automatic recovery reads project planning files only. Explicit session-catchup.py --metadata reads same-project local agent.factory/skills/planning-with-files⬇ 377 installsplanning-with-filesPersistent file-based planning for multi-step AI-agent work. Keeps task_plan.md, findings.md, and progress.md on disk; Gemini lifecycle hooks inject selected project planning context. Automatic recovery reads project planning files only. Explicit session-catchup.py --metadata reads same-project loca.gemini/skills/planning-with-files⬇ 377 installsplanning-with-filesPersistent file-based planning for multi-step AI-agent work. Keeps task_plan.md, findings.md, and progress.md on disk; lifecycle hooks inject selected project planning context. Automatic recovery reads project planning files only. Explicit session-catchup.py --metadata reads same-project local agent.hermes/skills/planning-with-files⬇ 377 installsplanning-with-filesPersistent file-based planning for multi-step AI-agent work. Keeps task_plan.md, findings.md, and progress.md on disk; Kiro skill instructions and steering state read selected project planning context. Recovery reads project planning files and their timestamps only, not agent transcript stores. This.kiro/skills/planning-with-files⬇ 377 installsplanning-with-filesPersistent file-based planning for multi-step AI-agent work. Keeps task_plan.md, findings.md, and progress.md on disk; lifecycle hooks inject selected project planning context. Automatic recovery reads project planning files only. Explicit session-catchup.py --metadata reads same-project local agent.mastracode/skills/planning-with-files⬇ 377 installsplanning-with-filesPersistent file-based planning for multi-step AI-agent work. Keeps task_plan.md, findings.md, and progress.md on disk; lifecycle hooks inject selected project planning context. Automatic recovery reads project planning files only. Explicit session-catchup.py --metadata reads same-project local agent.opencode/skills/planning-with-files⬇ 377 installsplanning-with-filesPersistent file-based planning for multi-step AI-agent work. Keeps task_plan.md, findings.md, and progress.md on disk; lifecycle hooks inject selected project planning context. Automatic recovery reads project planning files only. Explicit session-catchup.py --metadata reads same-project local agent.pi/skills/planning-with-files⬇ 377 installsplanning-with-files-arتخطيط مستمر قائم على الملفات لعمل وكلاء الذكاء الاصطناعي متعدد الخطوات. يحتفظ بملفات task_plan.md و findings.md و progress.md على القرص، وتحقن خطافات دورة الحياة سياق التخطيط المحدد للمشروع. تقرأ الاستعادة التلقائية ملفات تخطيط المشروع فقط. يمكن للأمر الصريح session-catchup.py --metadata فحص بيانات skills/i18n/planning-with-files-arplanning-with-files-dePersistente dateibasierte Planung für mehrstufige Arbeit mit KI-Agenten. Hält task_plan.md, findings.md und progress.md auf dem Datenträger; Lebenszyklus-Hooks speisen ausgewählten Planungskontext des Projekts ein. Die automatische Wiederherstellung liest nur die Planungsdateien des Projekts. Nur eiskills/i18n/planning-with-files-deplanning-with-files-esPlanificación persistente basada en archivos para tareas multipaso de agentes de IA. Mantiene task_plan.md, findings.md y progress.md en disco; los hooks del ciclo de vida inyectan contexto seleccionado de planificación del proyecto. La recuperación automática solo lee los archivos de planificación skills/i18n/planning-with-files-esplanning-with-files-zh用于多步骤 AI 代理工作的持久化文件规划系统。将 task_plan.md、findings.md 和 progress.md 保存在磁盘上,生命周期钩子会注入选定的项目规划上下文。自动恢复只读取项目规划文件。只有显式运行 session-catchup.py --metadata 才会检查本机同项目的会话元数据;--replay 可输出有长度限制且由 nonce 框定的同项目摘录。可选门禁仅在宿主支持时请求继续,绝不执行 Markdown 中声明的命令。本技能没有网络上传路径。适用于研究或需要 5 次以上工具调用的工作。触发词:任务规划、项目计划、制定计划、分解任务、多步骤规划、进度跟踪、skills/i18n/planning-with-files-zhplanning-with-files-zht用於多步驟 AI 代理工作的持久化檔案規劃。將 task_plan.md、findings.md 與 progress.md 保存在磁碟上,生命週期鉤子會注入選定的專案規劃內容。自動恢復只讀取專案規劃檔案;只有明確執行 session-catchup.py --metadata 才會檢查本機同一專案的代理工作階段中繼資料,--replay 則會輸出有界且以 nonce 框定的摘錄。選用的閘門模式只會在主機支援時要求繼續,而且絕不執行 Markdown 中宣告的命令。此技能沒有網路上傳路徑。適用於研究或需要超過 5 次工具呼叫的工作。觸發詞:任務規劃、專案計畫、制定計畫、分解任務、多步驟規劃、進skills/i18n/planning-with-files-zhtplanning-with-filesPersistent file-based planning for multi-step AI-agent work. Keeps task_plan.md, findings.md, and progress.md on disk; lifecycle hooks inject selected project planning context. Automatic recovery reads project planning files only. Explicit session-catchup.py --metadata reads same-project local agentskills/planning-with-files⬇ 377 installsDocumentation
README
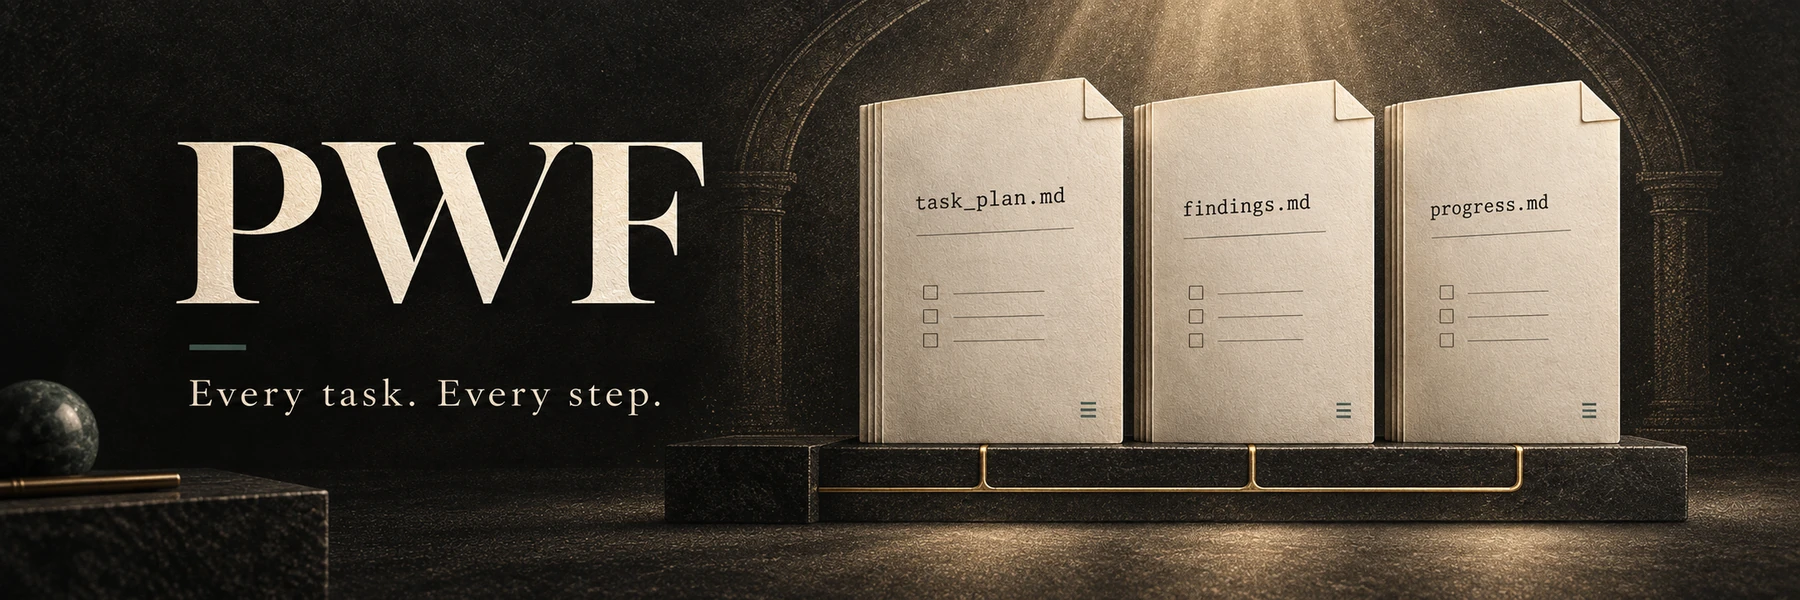
Planning with Files 
The planning skill your agent cannot ignore.
Not a prompt it might follow. A hook that fires every turn, a plan on disk that survives /clear, and 3 out of 3 blind A/B wins to show it works.
Sponsor
Your agent keeps the plan. Scrape.ly brings the web data.
Connect the Scrape.ly MCP server to Claude Code, Cursor or any MCP client: your agent searches the Store, runs a scraper and reads structured results, without leaving the task.
OSS code review support
Provided through CodeRabbit’s open-source program.
Your agent's context window dies. The plan does not.
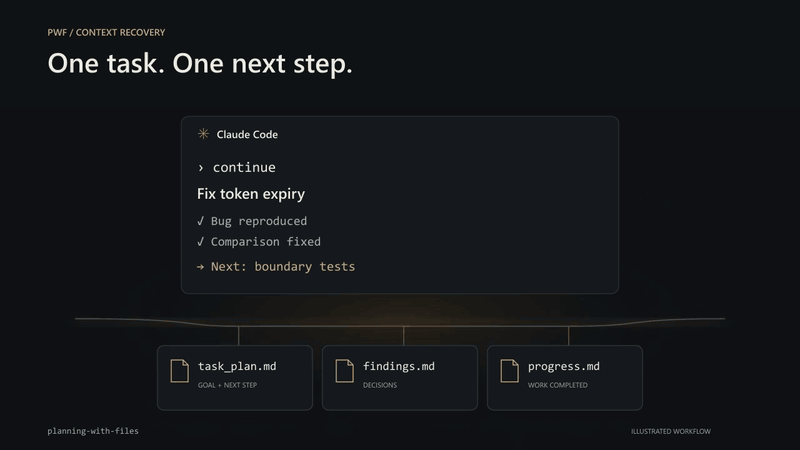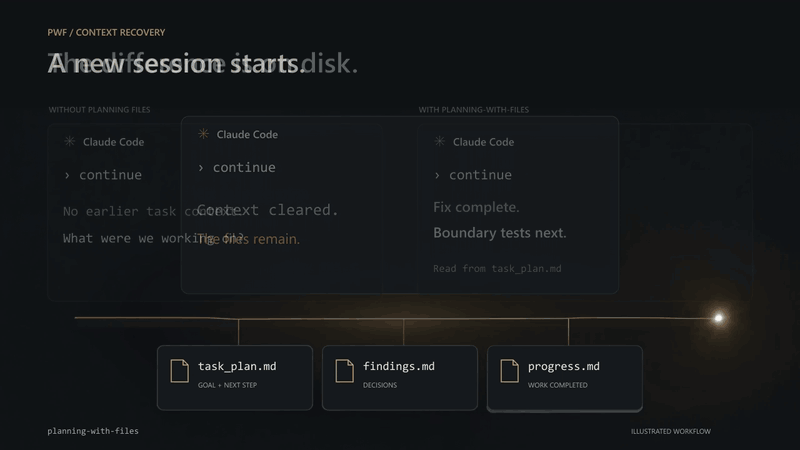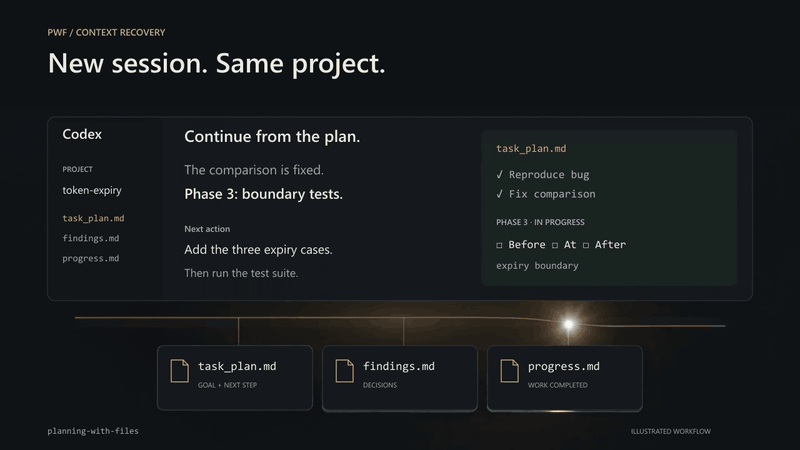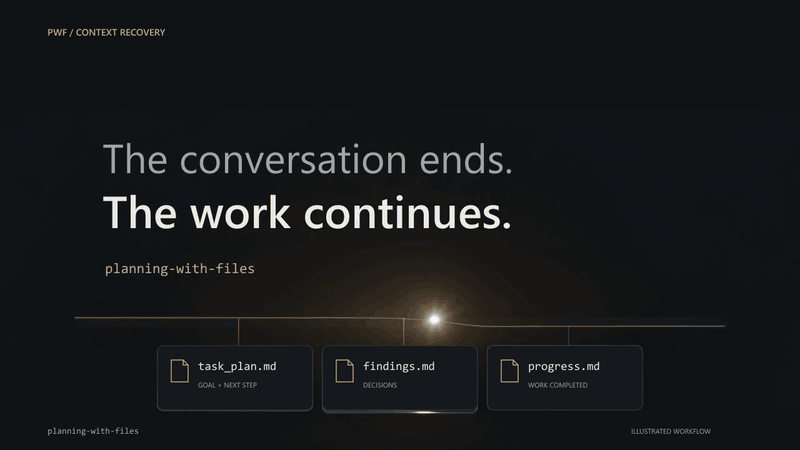
Persistent file-based planning for AI coding agents and long-running agent tasks: the skill keeps task_plan.md, findings.md, and progress.md on disk. Activated lifecycle hooks inject selected project planning context, so the plan survives context loss, /clear, crashes, and compaction. Automatic recovery reads project files only. Reading same-project local agent session records for aggregate counts or bounded replay requires an explicit catchup mode. Installs across 60+ agents via the Agent Skills standard, with native plugins for Claude Code, Codex CLI, Qoder CLI, Pi, Hermes Agent, OpenCode and DeepSeek Harness.




See it survive /clear · Install · Long-running tasks · First-class hosts
Open the Commands, Multi-agent runs, Benchmarks & more section below for the reference · Full install guide
Contributors
Code, documentation, and issue contributors. Select a portrait to open a GitHub profile or archived credit. Full credits.


🌍 Built with Planning with Files
Forks & Extensions
| Fork | Author | What They Built |
|---|---|---|
| devis | @st01cs | Interview-first workflow, /devis:intv and /devis:impl commands, guaranteed activation |
| multi-manus-planning | @kmichels | Multi-project support, SessionStart git sync |
| plan-cascade | @Taoidle | Multi-level task orchestration, parallel execution, multi-agent collaboration |
| agentfund-skill | @RioTheGreat-ai | Crowdfunding for AI agents with milestone-based escrow on Base |
| openclaw-github-repo-commander | @wd041216-bit | 7-stage GitHub repo audit, optimization, and cleanup workflow for OpenClaw |
| planning-with-sysspec | @tianshan | Spec-first extension adding structured module specifications, spec deltas and validation matrices (source) |
Used in the Wild
| Project | What It Is |
|---|---|
| lincolnwan/Planning-with-files-copilot-agent | Entire Copilot agent repo built around the planning-with-files skill |
| cooragent/ClarityFinance | AI finance agent framework, Planning-with-Files approach directly credited |
| oeftimie/vv-claude-harness | Claude Code harness built on Manus-style persistent markdown planning |
| jessepwj/CCteam-creator | Multi-agent team orchestration skill using file-based planning |
| smallnest/langgraphgo: Manus Agent | Go implementation of the planning-with-files pattern with persistent task plans, research notes and output files (source) |
| a5c-ai/babysitter | SDK planning, execution, session-recovery and verification processes adapted from planning-with-files (source) |
Skill Registries & Hubs
| Registry | What It Is |
|---|---|
| buzhangsan/skill-manager | Bilingual (EN/中文) Claude Code skill hub; planning-with-files installable one-click |
Bundled snapshots & adaptations
| Project | Verified relationship |
|---|---|
| benchflow-ai/skillsbench | Bundles planning-with-files v2.1.2 in its organize-messy-files benchmark task (snapshot) |
| sickn33/agentic-awesome-skills | Cross-agent skill collection shipping an adapted planning-with-files copy, originally imported at v2.1.2 (import) |
Built something? Open an issue to get listed!
Full list of everyone who made this project better: CONTRIBUTORS.md.
Quick Install
npx skills add OthmanAdi/planning-with-files --skill planning-with-files -g
All install methods: docs/installation.md.
Before and after /clear
Every coding agent loses its working memory when the context window resets. The plan does not have to die with it.
Built for long-running agent tasks
[!IMPORTANT] Most harnesses ship a to-do list that lives inside the context window. planning-with-files ships a plan that lives on disk, is re-injected every turn, is hash-attested, and can hold the agent's stop until the plan reports complete.
That is the difference between an agent that forgets after
/clear, compaction or a crash and one that resumes at the current phase. In the project's own measurements the plan on disk turned a 13.3-turn re-orientation into 5.0 turns, and the skill won 3 of 3 blind A/B comparisons (numbers and limits). Every mechanism below is a file on disk plus a hook, so it works the same on hour ten as on turn one.
The 3-file pattern
Context Window = RAM (volatile, limited)
Filesystem = Disk (persistent, unlimited)

→ Anything important gets written to disk.
The skill keeps your plan, findings, and progress in your project:
your-project/
├── task_plan.md   ← phases + checkboxes; the resume point after /clear
├── findings.md    ← research notes and decisions, appended as you go
└── progress.md    ← session log and test results
Parallel tasks get isolated directories instead: .planning/YYYY-MM-DD-slug/ with the same three files, selected via .active_plan (v2.36.0+). Plain markdown, gitignored by default, no runtime state anywhere else.
The pattern is the one Manus described before Meta acquired it for $2 billion on December 29, 2025, eight months and $100M+ of revenue after launch:
"Markdown is my 'working memory' on disk. Since I process information iteratively and my active context has limits, Markdown files serve as scratch pads for notes, checkpoints for progress, building blocks for final deliverables." — Manus AI
First-class hosts: native plugins
[!TIP] Native integrations load planning context, provide progress reminders and support a completion gate. Commands and model-callable tools depend on the host; Qoder CLI loads the skill and lifecycle hooks without the Claude-specific command prompts. The platform setup guides describe each integration and the standard Agent Skills routes.
🌐 Available in 5 other languages
🇸🇦 العربية / Arabic
npx skills add OthmanAdi/planning-with-files --skill planning-with-files-ar -g
🇩🇪 Deutsch / German
npx skills add OthmanAdi/planning-with-files --skill planning-with-files-de -g
🇪🇸 Español / Spanish
npx skills add OthmanAdi/planning-with-files --skill planning-with-files-es -g
🇨🇳 中文版 / Chinese (Simplified)
npx skills add OthmanAdi/planning-with-files --skill planning-with-files-zh -g
🇹🇼 正體中文版 / Chinese (Traditional)
npx skills add OthmanAdi/planning-with-files --skill planning-with-files-zht -g
These are real translations, not an English body with a translated description: the SKILL.md prose, the templates, and the user-facing output of check-complete, init-session and session-catchup are all localized. The status tokens stay literal English (**Status:** complete) on purpose, because check-complete.sh matches them with grep -F, so translating them would disable the completion gate.
Since v3.10.0 the variants also ship the full script surface: attestation, the Stop gate, the ledger, phase status and plan-doctor used to be canonical-only, which quietly made every non-English install a subset install. Full details, including what changed on the plugin route in v3.11.0, are in docs/languages.md.
They live under skills/i18n/, one directory deeper than the canonical skill. The install commands above are unchanged, because npx skills add resolves --skill by skill name across the whole repository. The Claude Code plugin scan reads skills/*/SKILL.md without recursing, so the plugin route registers the canonical skill alone and no longer carries five extra descriptions in every session's system prompt. On that route the /plan-ar, /plan-de, /plan-es, /plan-zh and /plan-zht commands read the translated skill from disk instead of invoking it by name.
Enhanced Support: per-IDE setup guides
| IDE | Installation Guide | Integration |
|---|---|---|
| Claude Code | Installation | Plugin + SKILL.md + Hooks |
| Cursor | Cursor Setup | Skills + hooks.json |
| GitHub Copilot | Copilot Setup | Hooks (incl. errorOccurred) |
| Mastra Code | Mastra Setup | Skills + Hooks |
| Gemini CLI | Gemini Setup | Skills + Hooks |
| Kiro | Kiro Setup | Agent Skills |
| Codex | Codex Setup | Skills + Hooks |
| Qoder CLI | Installation | Skill + seven lifecycle hooks; Bash and Python 3.10+ required |
| Hermes Agent | Hermes Setup | Skill + native plugin (tools, /pwf, pre_llm_call, post_tool_call, pre_verify gate), CLI and Desktop |
| CodeBuddy | CodeBuddy Setup | Skills + Hooks |
| FactoryAI Droid | Factory Setup | Skills + Hooks |
| OpenCode | OpenCode Setup | Native plugin opencode-planning-with-files (chat.message injection, write reminders, compaction flush, session.idle gate, pwf_* tools, /pwf commands) + skill |
| DeepSeek Harness | DeepSeek Harness Setup | Native plugin dsh-planning-with-files (agent/pre-step injection, write reminders, post-compaction restore, agent/turn-stopping gate, pwf_* tools, /pwf commands) + skill |
Standard Agent Skills: discovery paths
| IDE | Installation Guide | Skill Discovery Path |
|---|---|---|
| Continue | Continue Setup | .continue/skills/ + .prompt files |
| Pi Agent | Pi Agent Setup | .pi/skills/ (npm package) |
| OpenClaw | OpenClaw Setup | .openclaw/skills/ (docs) |
| Autohand Code | Autohand Code Setup | ~/.autohand/skills/ or .autohand/skills/ |
| Antigravity | Antigravity Setup | .agent/skills/ (docs) |
| Kilocode | Kilocode Setup | .kilocode/skills/ (docs) |
| AdaL CLI (Sylph AI) | AdaL Setup | .adal/skills/ (docs) |
Note: If your IDE uses the legacy Rules system instead of Skills, see the
legacy-rules-supportbranch.
Sandbox runtimes
| Runtime | Status | Guide | Notes |
|---|---|---|---|
| BoxLite | ✅ Documented | BoxLite Setup | Run Claude Code + planning-with-files inside hardware-isolated micro-VMs |
BoxLite is a sandbox runtime, not an IDE. Skills load via ClaudeBox, BoxLite's official Claude Code integration layer.
❓ FAQ
How do I stop my coding agent from losing its plan after /clear or a crash?
The plan lives on disk in task_plan.md, findings.md, and progress.md, not only in the context window. At the start of each turn the UserPromptSubmit hook re-injects selected active-plan context, and after a /clear or a new session the skill re-reads project files from disk. This automatic path does not inspect agent transcript stores.
What is the difference between planning-with-files and an agent memory tool?
Agent memory tools (vector stores, knowledge graphs) help an agent recall facts from past sessions. planning-with-files manages active execution state: the phases, status, dependencies, and completion check for the task the agent is working on right now. The problem it solves is planning continuity, not retrieval, and the two are complementary.
How does this prevent context rot?
Context rot is the drift that sets in as the context window fills and earlier instructions get crowded out. Because the plan is re-injected at the start of each turn from disk, the goals and phase status stay in the model's attention window as the conversation grows. This is an implementation of what Anthropic calls structured note-taking: write durable state to files outside the window, then read it back in when needed.
Which coding agents does this work with?
…
Releases
Recent versions
v3.28.1v3.28.1 - Attestation refusals and selector safetyv3.28.0v3.28.0 - Archive and restore finished plansv3.27.0v3.27.0 - Agent-readable plan inventoryv3.26.0v3.26.0 - Claude subagent isolation and hook fixesv3.25.2v3.25.2 - trackable plan creation and harness fixesv3.25.1v3.25.1 - status validity and optional eval